projects
Research and engineering projects in robotics, control, simulation, numerical modelling, and mechatronic systems.
control research
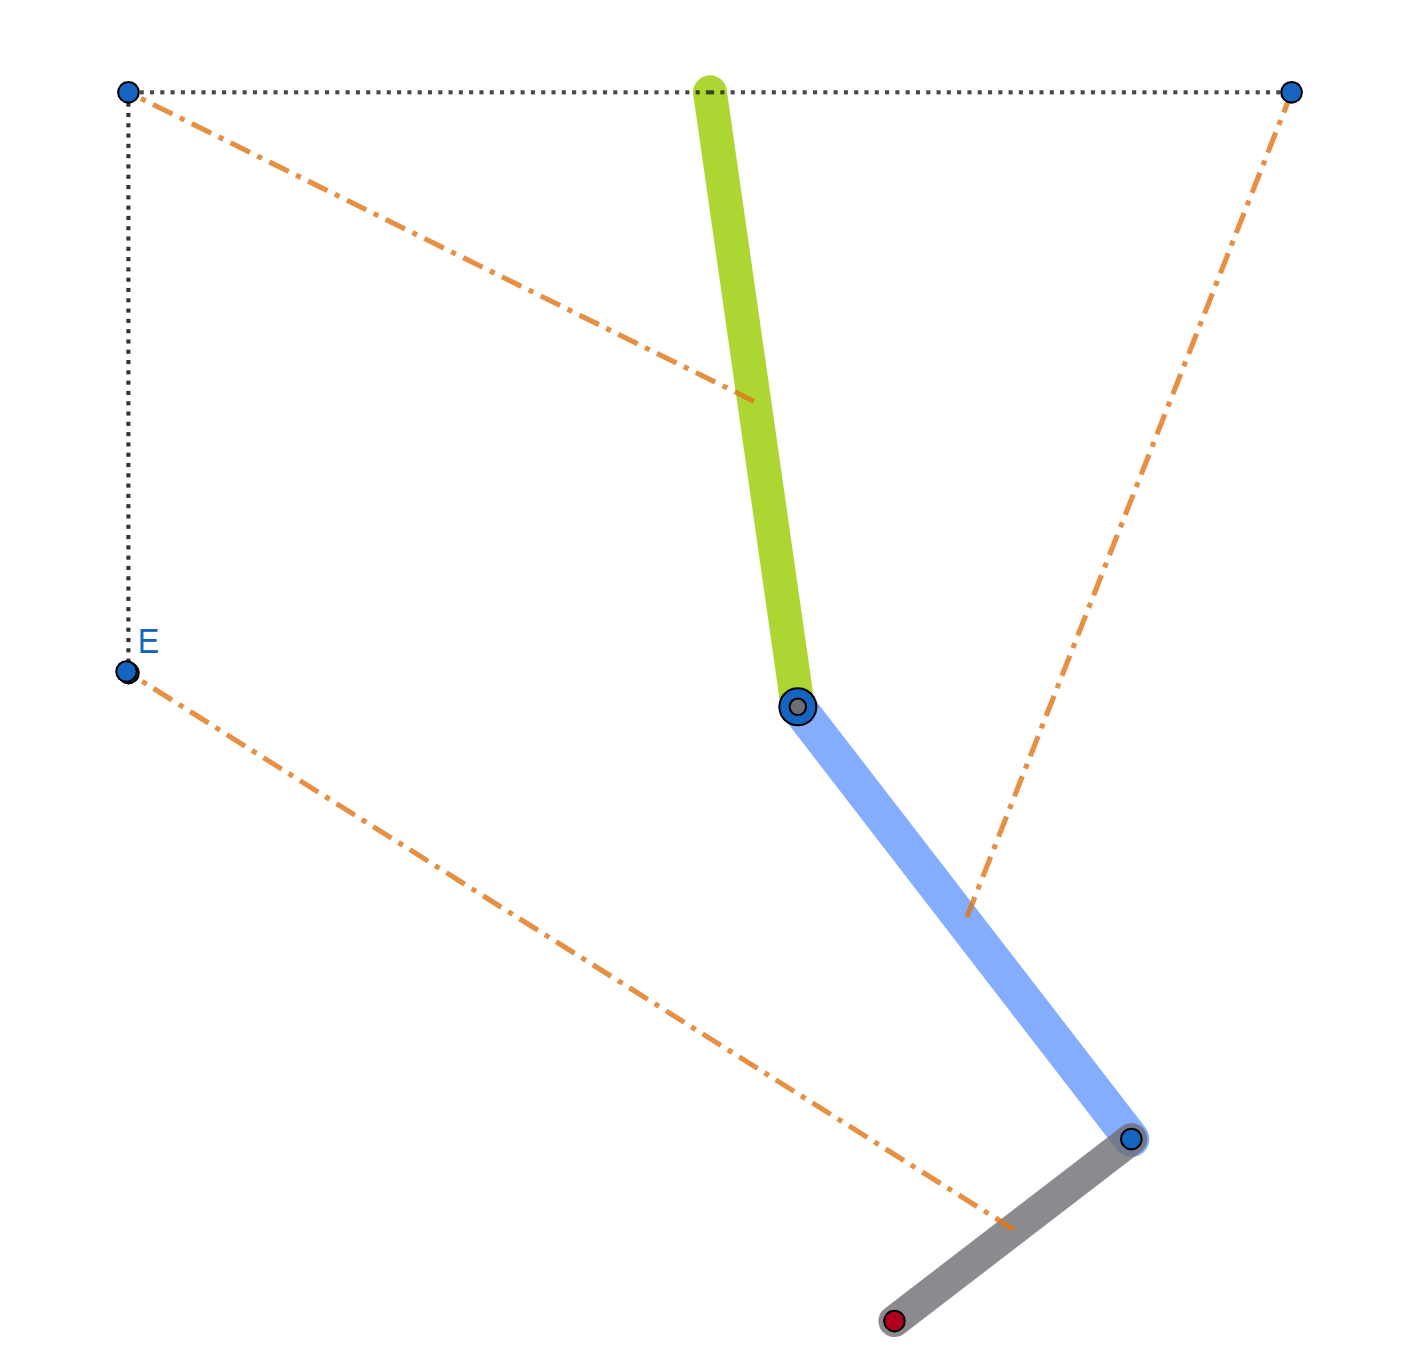
Residual DDPG + Computed Torque Control for a Cable-Driven Lower-Limb Rehabilitation Robot
Simulation-based M.Sc. research on bounded residual DDPG augmentation of computed torque control for a planar three-cable lower-limb rehabilitation robot, with disturbance, uncertainty, joint-limit, cable-feasibility, and robustness analysis.
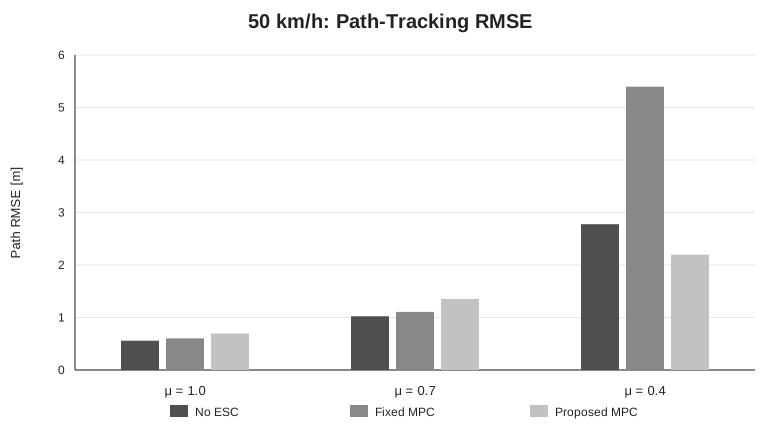
Friction-Aware MPC with Lateral-Slip Constraint Back-Off
Simulation-based research on friction-aware linear MPC for vehicle path following and stability under reduced tire-force capacity, parameter mismatch, and high-speed stress testing.
robotics control
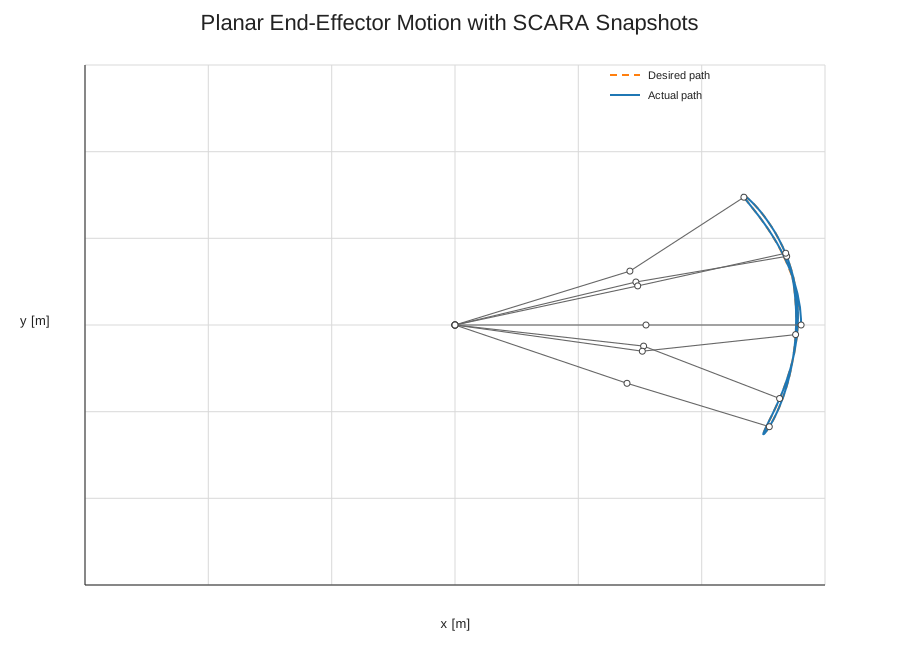
4-DOF SCARA Kinematics, Dynamics & Computed-Torque Tracking
MATLAB project for 4-DOF SCARA forward kinematics, task-Jacobian analysis, Lagrangian dynamics, workspace visualization, model consistency checks, and computed-torque trajectory tracking.
robotics
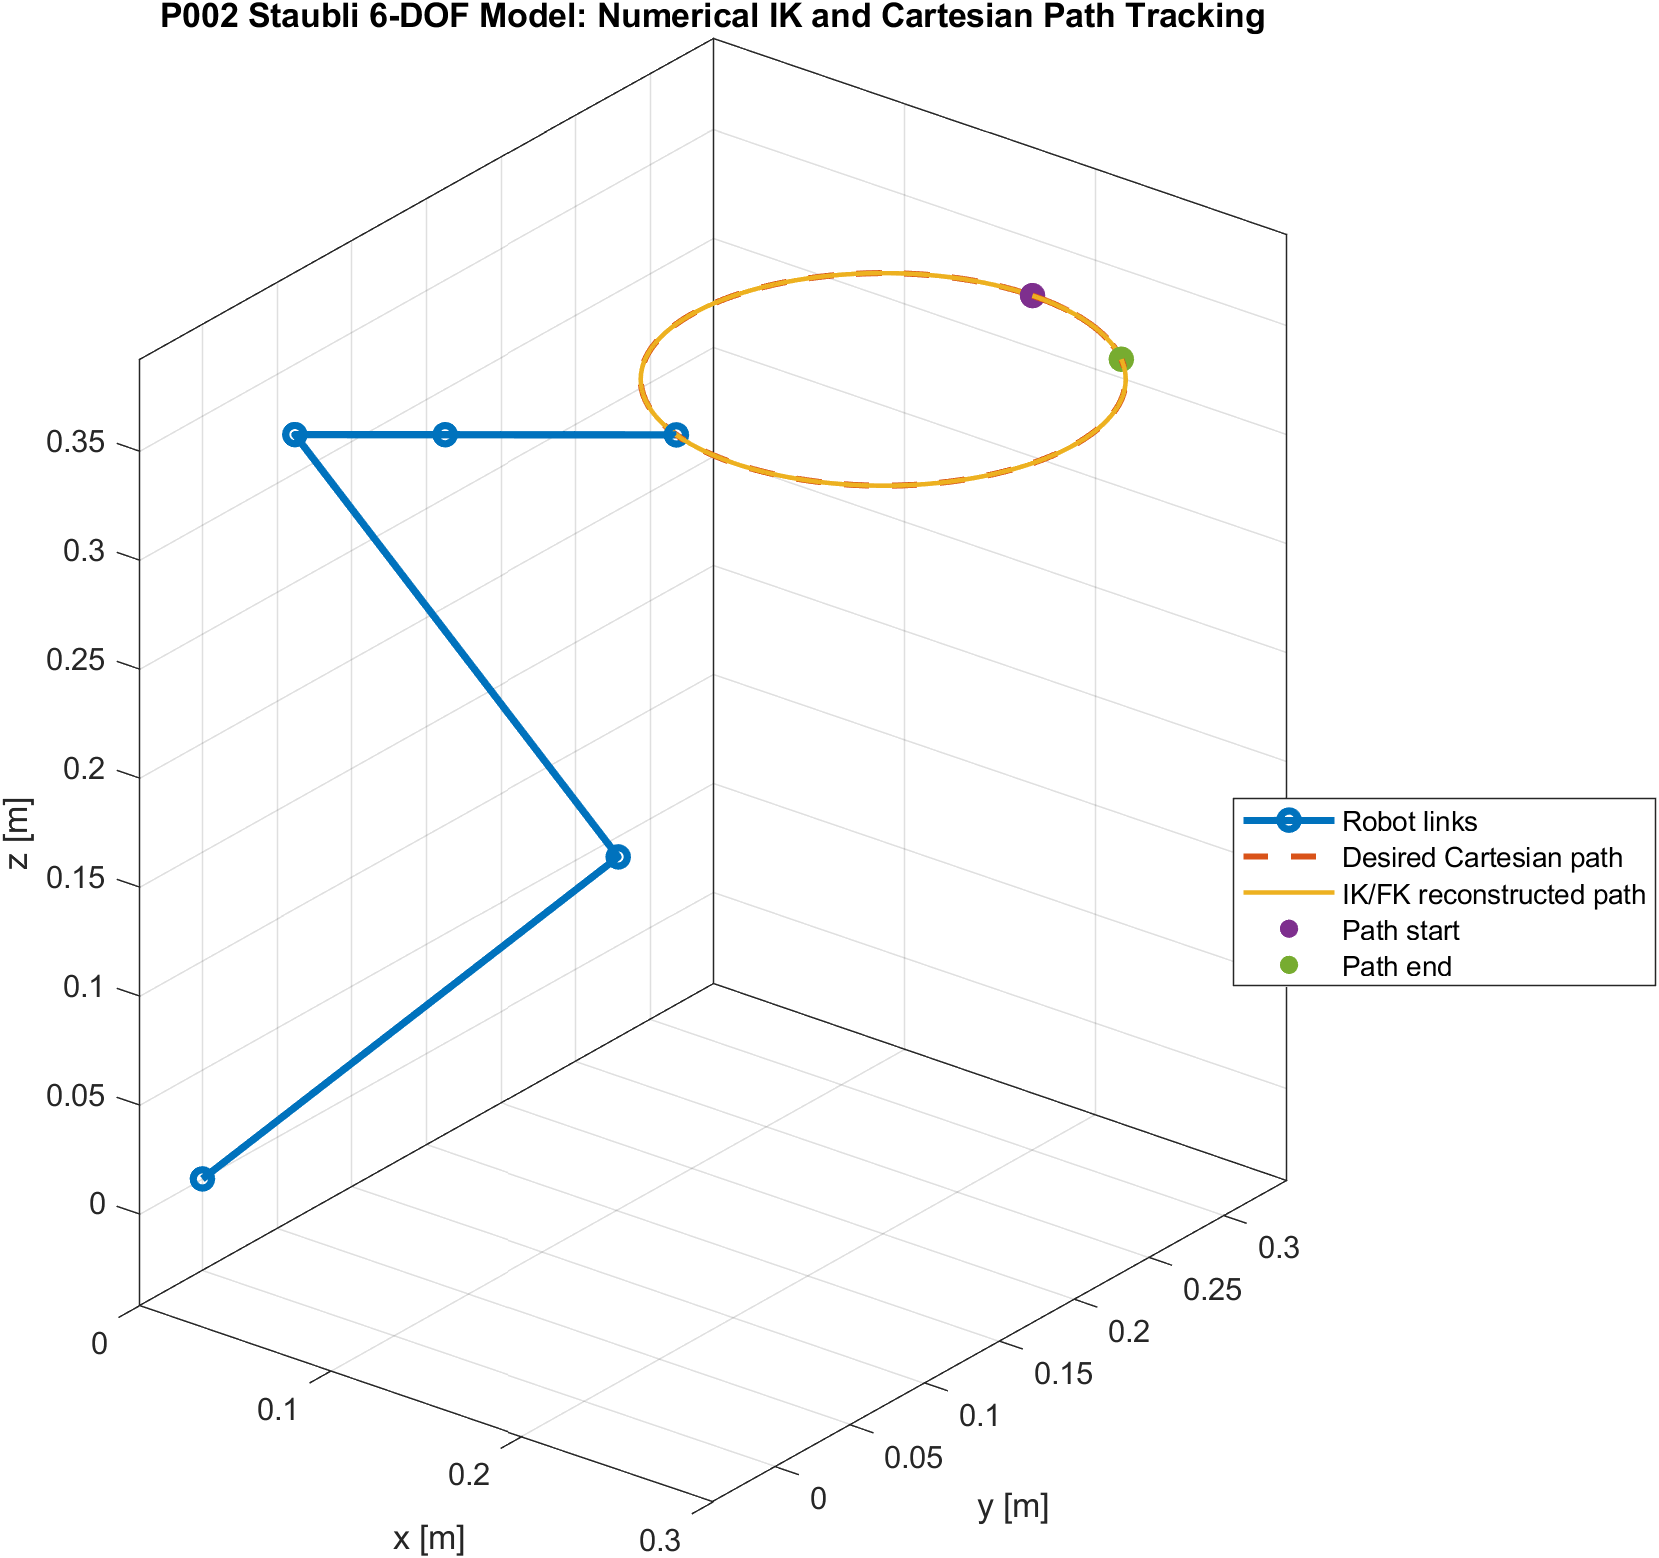
6-DOF Serial Robot Kinematics and Numerical Inverse Kinematics
MATLAB project for forward kinematics, position-only damped-least-squares inverse kinematics, Cartesian trajectory reconstruction, and position-Jacobian analysis of a 6-DOF serial robot model.
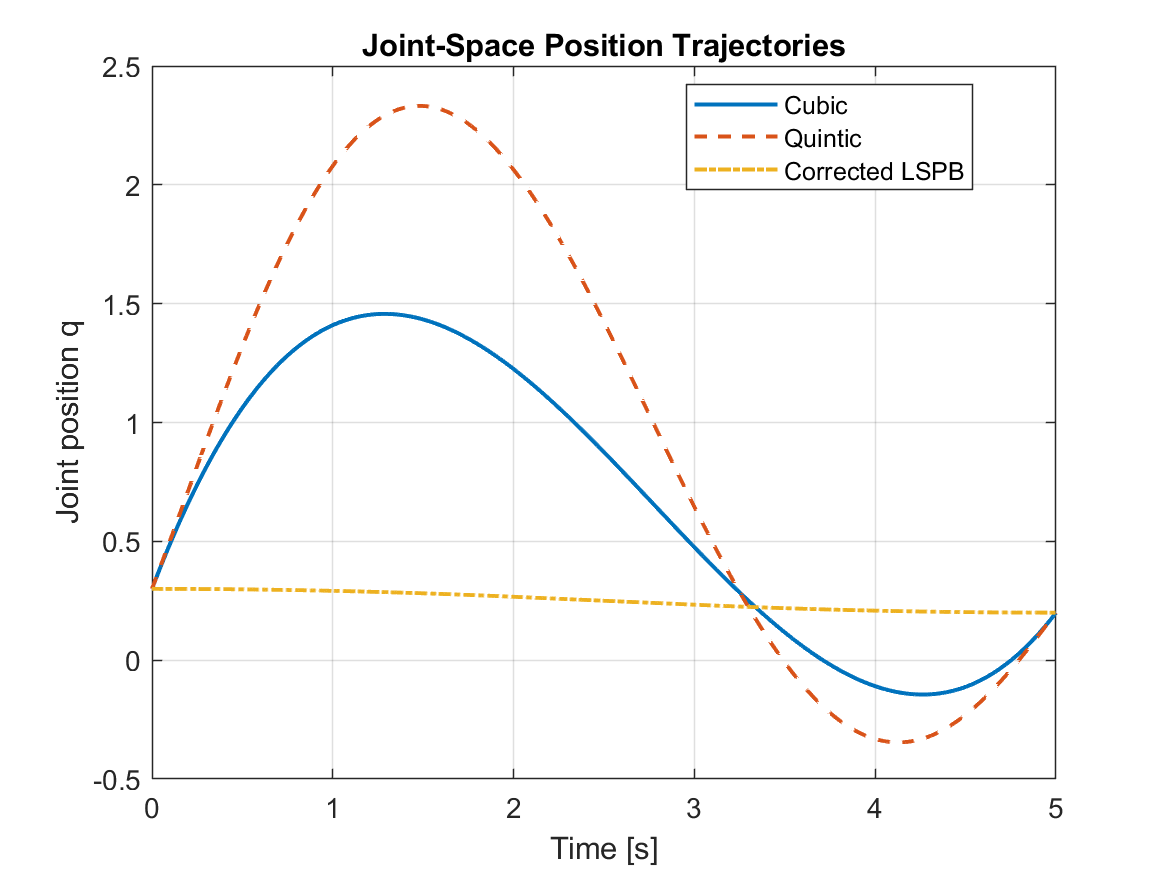
Polynomial Robot Motion Planning
MATLAB project comparing cubic, quintic, and corrected LSPB joint-space trajectories with boundary-condition verification, trajectory derivatives, and explicit correction of archived formulation errors.
robotics navigation
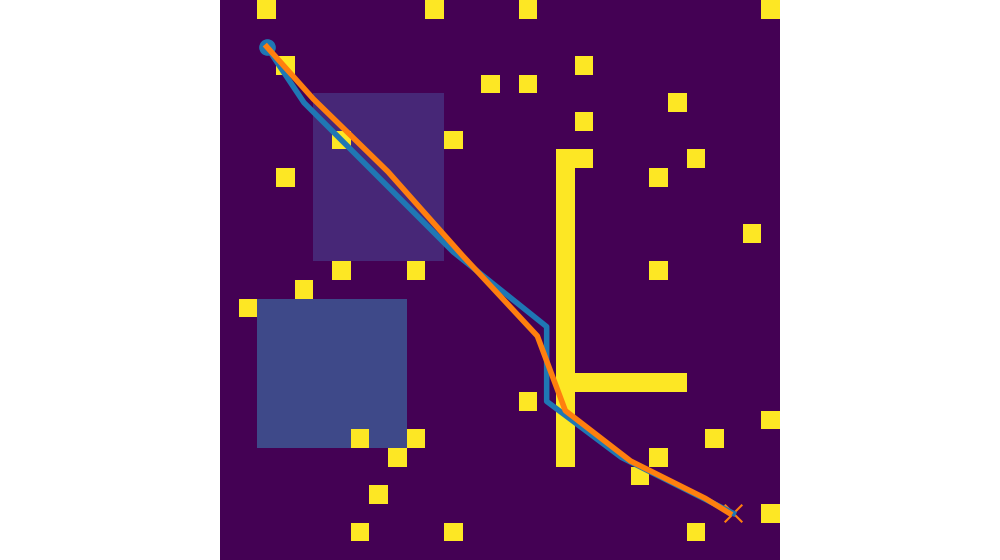
Mobile Robot Navigation Basics
Small Python practice project for terrain grid maps, A* path planning, disturbed tracking, and simple mobile robot simulation.
vehicle dynamics
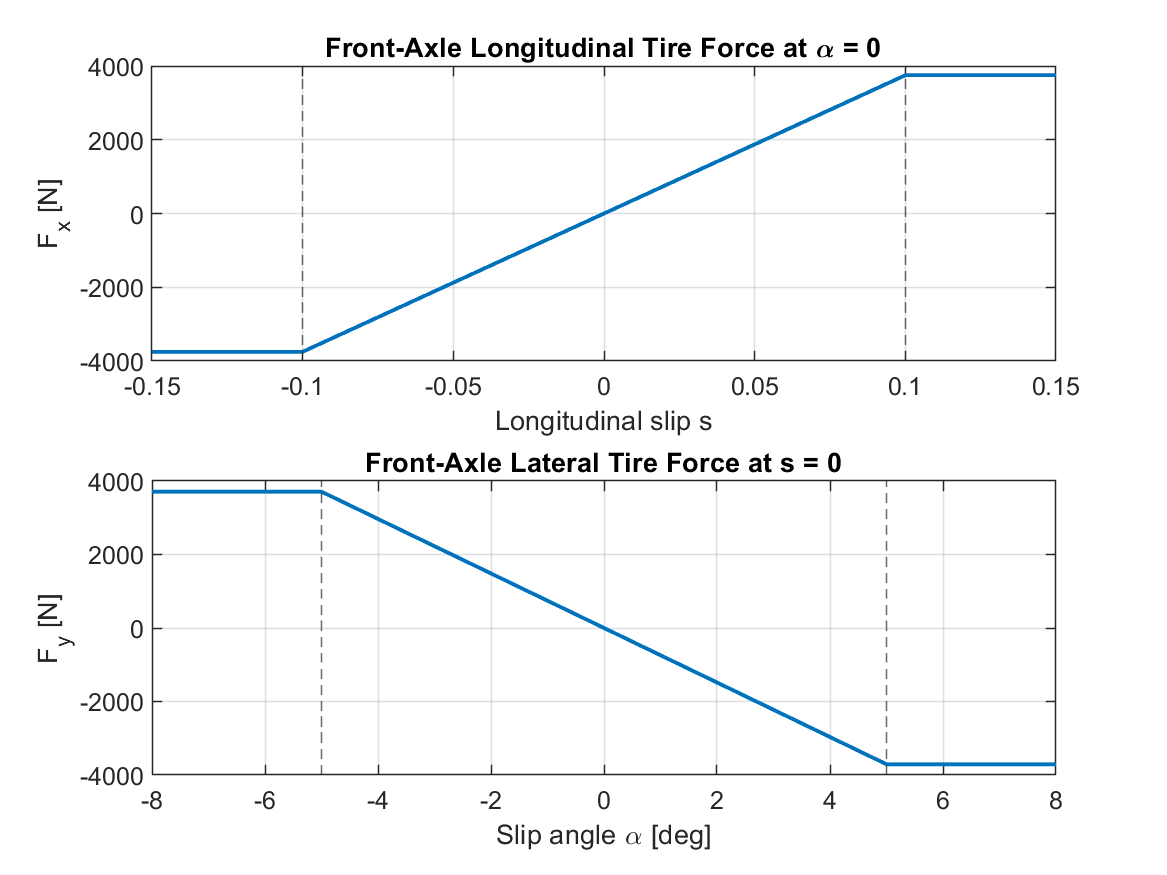
Nonlinear Vehicle Dynamics, Tire-Force Modeling & Linearization
MATLAB project for five-state nonlinear vehicle dynamics, combined-slip tire-force modeling, tire saturation, straight-line operating-point linearization, and nonlinear-versus-linear analysis.
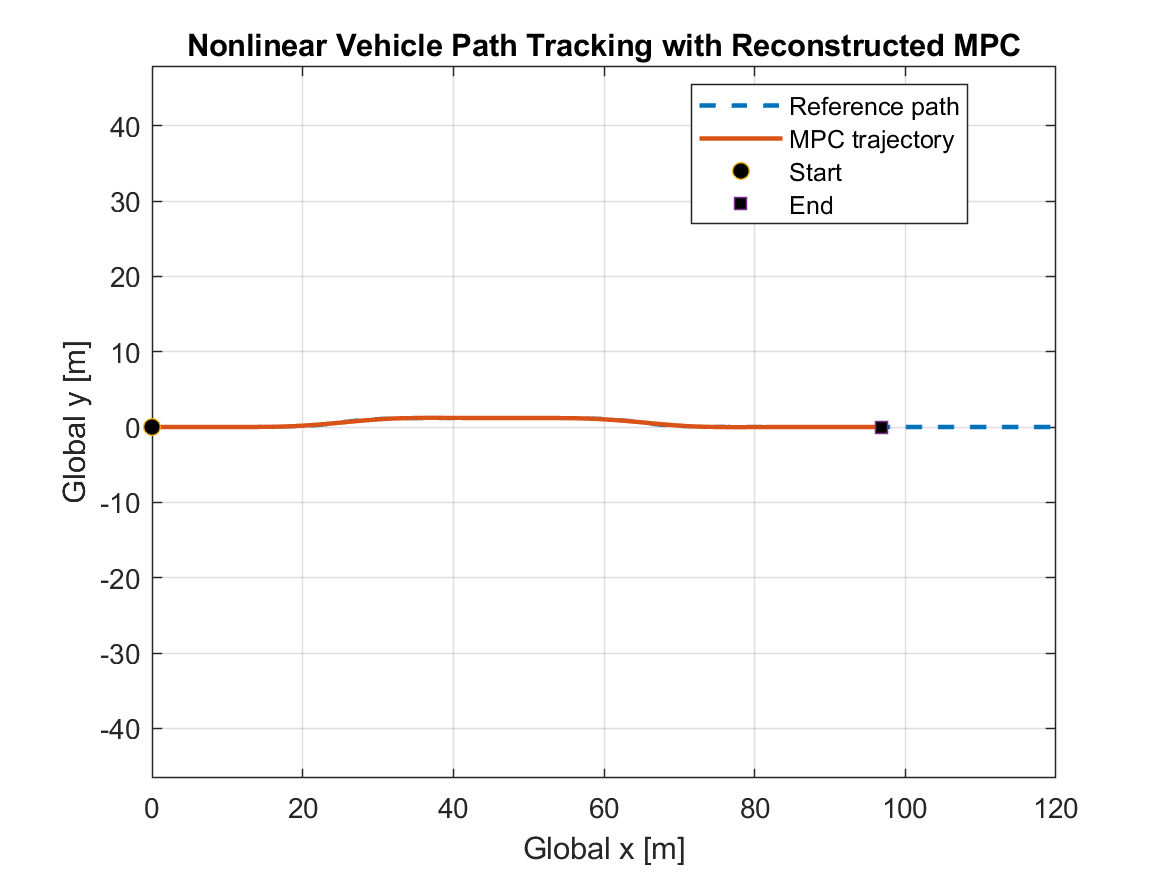
Vehicle Lateral Dynamics with Model Predictive Control
MATLAB project combining a nonlinear five-state vehicle model with operating-point linearization and a reconstructed finite-horizon MPC for lateral path tracking.
robotics software
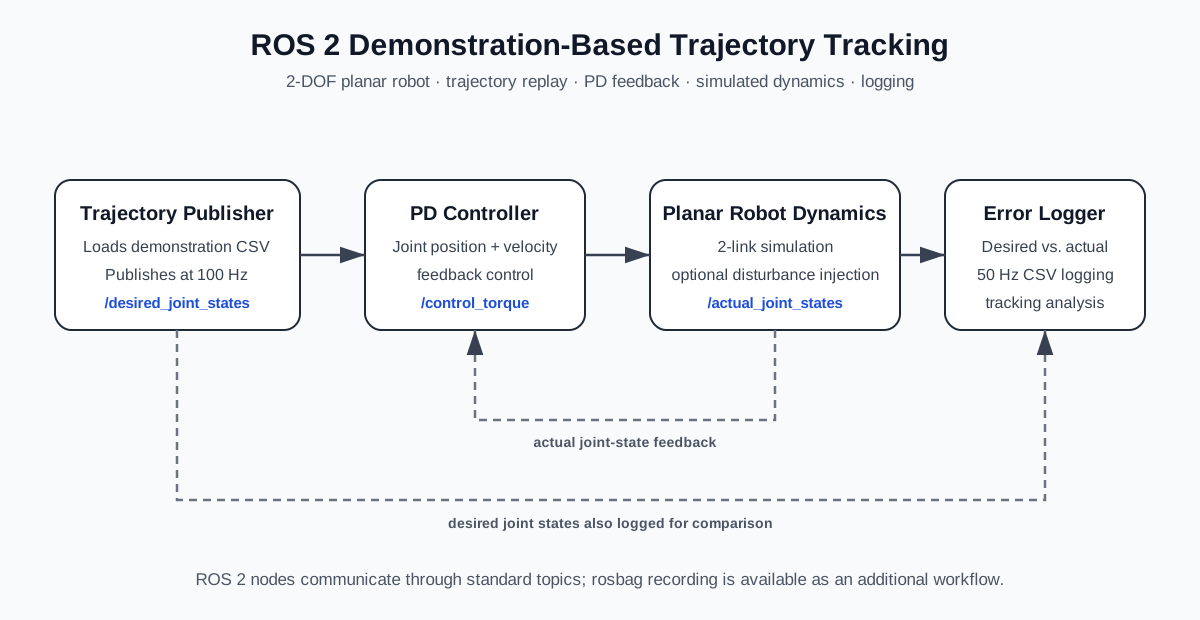
ROS 2 Demonstration-Based Trajectory Tracking for a 2-DOF Planar Robot
ROS 2 Python project for demonstration-trajectory replay, joint-space PD control, simulated 2-DOF planar robot dynamics, disturbance injection, and quantitative tracking-error analysis.
robotics sensing
Tactile Force Contact Detection
Signal-processing and classification-oriented project for detecting contact states from tactile or force-related data.
control hardware
Ball and Beam PID Control with Arduino
Real hardware control project using PID control and Arduino for stabilizing a ball-and-beam system.
control systems
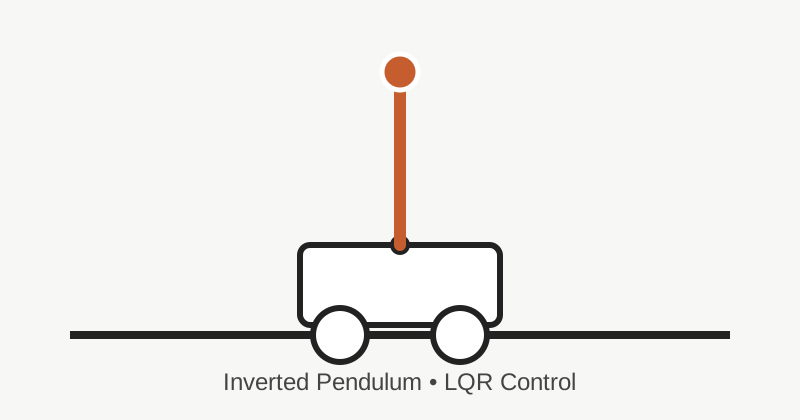
Inverted Pendulum: State-Space Analysis, LQR & Animation
MATLAB project for inverted-pendulum state-space analysis, controllability and observability, continuous-time LQR design, regulation tradeoffs, simulation, and animation.
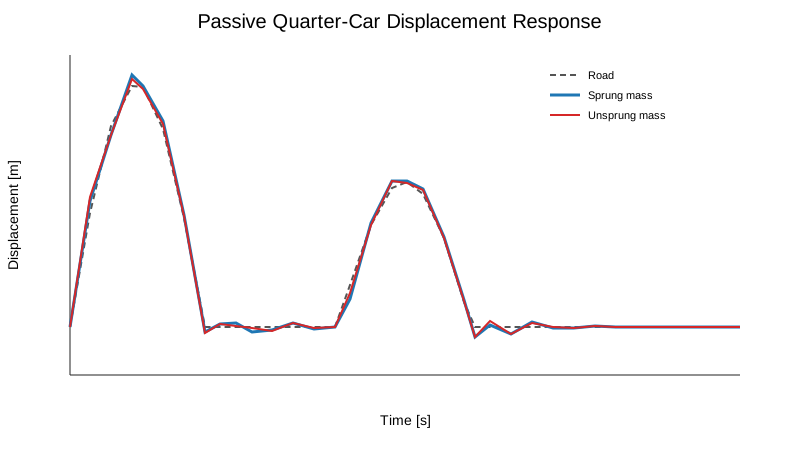
Quarter-Car Suspension Dynamics & Road-Disturbance Response
MATLAB project for passive quarter-car suspension dynamics, road-disturbance response, modal analysis, frequency response, and damping-sensitivity evaluation.
numerical methods
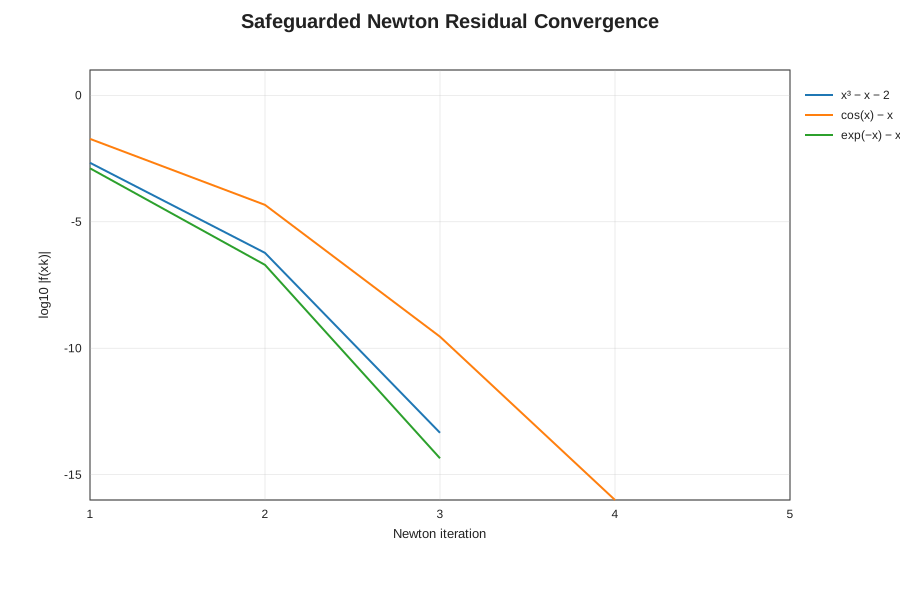
Numerical Calculus: Newton–Raphson App & Validation
MATLAB App Designer Newton–Raphson project with safeguarded root finding, numerical validation, convergence analysis, initial-guess sensitivity, and explicit failure-mode diagnostics.